omp-map-gpt4o-ground-001
dom · homebot-dom · 2026-11-02 19:08 ·
homebot-dom/runs/omp-map-gpt4o-ground-001MP4 · 48.5 KB · pełny ekran w playerze
room
living_ground · rev 3| wymiar | wartość | status |
|---|---|---|
| width | — | opposing_planes_not_observed |
| length | — | opposing_planes_not_observed |
| height | — | floor_or_ceiling_not_observed |
ściany: —
obiekty: collection_bin
skillhouse-ground
modelopenai/gpt-4o
profilgpu
LLM / koszt7 calli · $0.131
ag. limity7 req · 2 seq · 9 tools
czas misji25.7s
calle LLM
7
tool calls
9
koszt zadania
$0.131
tokeny (sum)
78,494
in / out
20,951 / 711
cache R/W
56,832 / 0
czas modelu
22.8s
Calle LLM na zadanie
| # | czas | co zrobił (tool + wynik) | tokeny | koszt |
|---|---|---|---|---|
| 1 | 2.1s toolUse | robot_capabilities Odkryj zdolności robota w kontekście MCP v4 mode=SIMULATION_ONLY robot_observe Pobierz pierwsze RGB-D i sensory dla pomieszczenia startowego {"observation_id":"obs-10066ff8-1-350","session_id":"10066ff8","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P… | 5,793 in 5715 · out 78 | $0.015 |
| 2 | 6.3s toolUse | room_measure Zmierz nową obserwację dla pokoju, uwzględniając obecną kalibrację {"memory_revision":1,"dimensions":{"width":{"value_m":null,"status":"opposing_planes_not_observed"},"length":{"value_m"… | 9,177 in 9136 · out 41 | $0.023 |
| 3 | 2.5s toolUse | robot_observe Pobierz kolejną obserwację RGB-D i sensory {"observation_id":"obs-10066ff8-2-350","session_id":"10066ff8","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P… robot_look Obróć kamerę w bezpiecznym zakresie aby zbadać więcej pomieszczenia rejected | 9,433 in 229 · out 116 · cR 9088 · cW 0 | $0.013 |
| 4 | 1.6s toolUse | room_measure Zmierz kolejną obserwację dla pokoju po zmianie widoku {"memory_revision":2,"dimensions":{"width":{"value_m":null,"status":"opposing_planes_not_observed"},"length":{"value_m"… | 11,966 in 2588 · out 34 · cR 9344 · cW 0 | $0.018 |
| 5 | 2.6s toolUse | robot_observe Pobierz trzecią unikalną obserwację RGB-D i sensory {"observation_id":"obs-10066ff8-3-350","session_id":"10066ff8","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P… robot_look Obróć kamerę na nowe miejsce aby spróbować uchwycić więcej przestrzeni rejected | 12,223 in 329 · out 118 · cR 11776 · cW 0 | $0.017 |
| 6 | 2.8s toolUse | room_measure Zaktualizuj pomiary na bazie trzeciej obserwacji {"memory_revision":3,"dimensions":{"width":{"value_m":null,"status":"opposing_planes_not_observed"},"length":{"value_m"… | 14,736 in 2670 · out 34 · cR 12032 · cW 0 | $0.022 |
| 7 | 4.8s stop | **Raport z mapowania pomieszczenia:** 1. **Zmierzono:** - Zidentyfikowano lokalizację pojemnika (obiekt: collection_bin). - Widoczna powierzchnia podłogi jest odnotowana, ale brak pełnych danych na temat przeciws… | 15,166 in 284 · out 290 · cR 14592 · cW 0 | $0.022 |
Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).
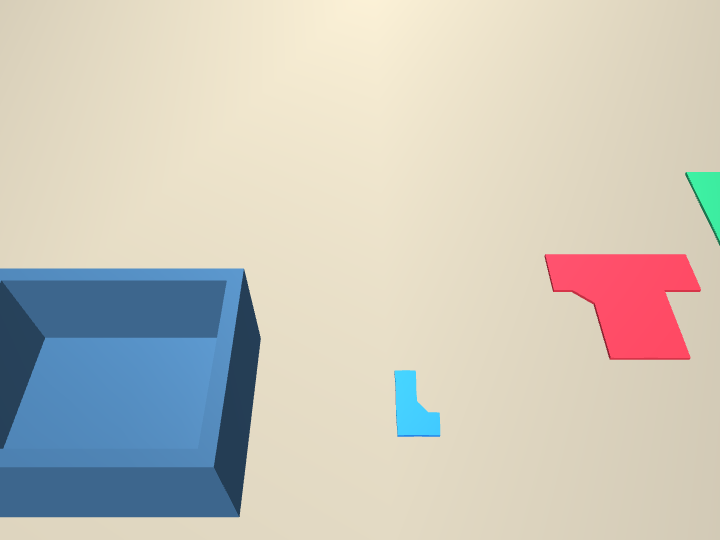
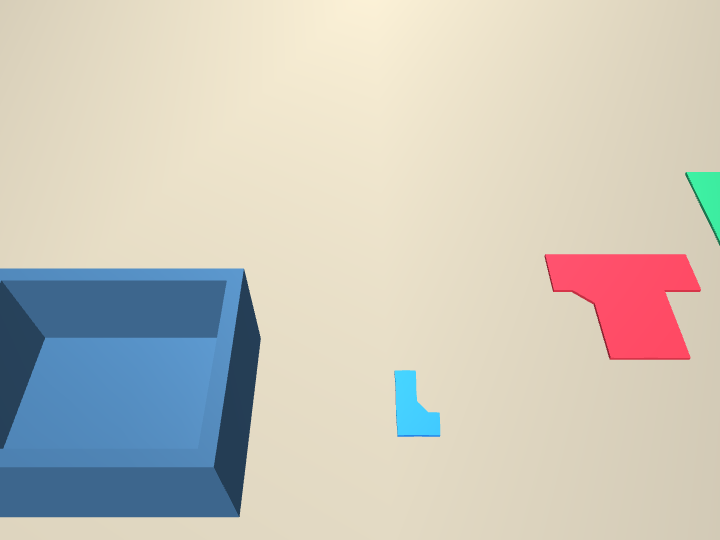
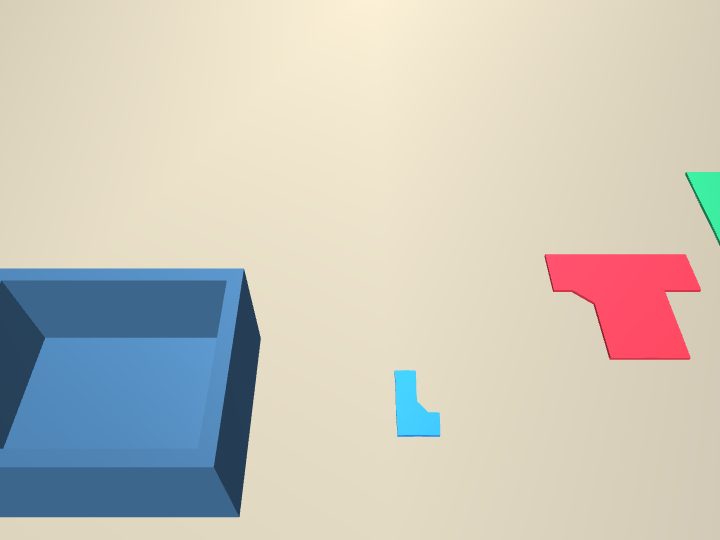
evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003981376356301913
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976800826699878
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976144772117645
    }
  },
  "events": [],
  "sim_time_s": 0.7000000000000005,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": 8.355828800962518e-38,
      "handle_angle_rad": -4.155420223110155e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -7.54215544090371e-09,
      "handle_angle_rad": 6.22153966751848e-19,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -4.155420223108506e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -7.542155440900925e-09,
      "handle_angle_rad": -4.457617378534617e-18,
      "latch_active": true
    },
    "g_wc": {
      "hinge_angle_rad": -7.534199941256135e-09,
      "handle_angle_rad": -2.208855896820167e-18,
      "latch_active": true
    },
    "g_vestibule": {
      "hinge_angle_rad": -7.534199941256135e-09,
      "handle_angle_rad": -2.208855896820167e-18,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -7.542155440901597e-09,
      "handle_angle_rad": -7.199704968859303e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}