omp-map-gpt4o-ground-004-length
dom · homebot-dom · 2026-11-02 19:30 ·
homebot-dom/runs/omp-map-gpt4o-ground-004-lengthMP4 · 334.6 KB · pełny ekran w playerze
room
living_ground · rev 2| wymiar | wartość | status |
|---|---|---|
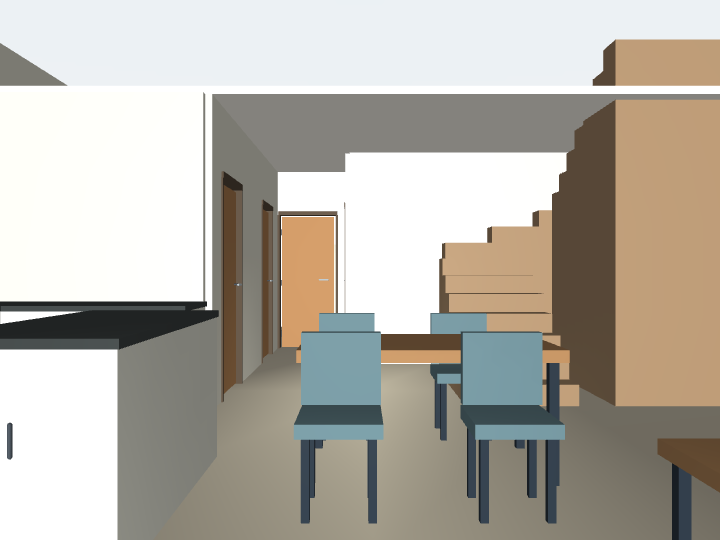
| width | 1.958 m | measured_across_calibrated_views |
| length | 2.691 m | measured_across_calibrated_views |
| height | 2.701 m | observed_floor_and_ceiling |
ściany: wall_main_w, wall_office_s, wall_office_w, wall_wc_e, wall_vest_e, wall_vest_s
obiekty: collection_bin, g_entrance_frame, g_garage_utility_frame, g_office_frame, g_wc_frame, g_vestibule_frame, g_vestibule, g_coffee, g_kitchen_n, g_island, g_dining, g_chair0, g_chair1, g_chair2, g_chair3
skillhouse-ground
modelopenai/gpt-4o
profilgpu
LLM / koszt6 calli · $0.131
ag. limity6 req · 3 seq · 10 tools
czas misji22.1s
calle LLM
6
tool calls
10
koszt zadania
$0.131
tokeny (sum)
76,875
in / out
23,473 / 666
cache R/W
52,736 / 0
czas modelu
16.0s
Calle LLM na zadanie
| # | czas | co zrobił (tool + wynik) | tokeny | koszt |
|---|---|---|---|---|
| 1 | 2.1s toolUse | robot_capabilities Discover robot capabilities, dimensions, and memory context for initial setup mode=SIMULATION_ONLY mission_memory_read Check past memory for measurement context {"revision":0,"agent_notes":null} robot_observe Gather a fresh observation from the robot's sensors {"observation_id":"obs-6a2d6a9a-1-350","session_id":"6a2d6a9a","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P… | 6,357 in 6268 · out 89 | $0.017 |
| 2 | 2.9s toolUse | robot_look Adjust the camera to look directly at the walls for better visibility ok room_measure Attempt to measure room dimensions post adjustment {"memory_revision":1,"dimensions":{"width":{"value_m":null,"status":"opposing_planes_not_observed"},"length":{"value_m"… | 9,833 in 9730 · out 103 | $0.025 |
| 3 | 2.5s toolUse | robot_move_base Rotate right to find the missing wall along the Y axis rejected robot_observe Observe the scene again after rotation to capture the room's dimensions {"observation_id":"obs-6a2d6a9a-2-913","session_id":"6a2d6a9a","time_s":1.826,"rgb_path":"/home/pawel/Documents/HomeBot… | 10,159 in 320 · out 111 · cR 9728 · cW 0 | $0.014 |
| 4 | 2.4s toolUse | room_measure Measure room dimensions based on the new observation {"memory_revision":2,"dimensions":{"width":{"value_m":1.9579,"sigma_floor_m":0.02,"source_walls":["wall_main_w","wall_w… robot_move_base Rotate left to continue searching for the Y-axis wall ok | 16,361 in 6267 · out 110 · cR 9984 · cW 0 | $0.029 |
| 5 | 2.9s toolUse | mission_memory_write Save the observed walls and dimensions to agent memory after successful measurement {"revision":1,"kind":"agent_mission_notes","notes":"Walls: [wall_main_w, wall_office_s, wall_office_w, wall_wc_e, wall_… | 16,947 in 606 · out 85 · cR 16256 · cW 0 | $0.023 |
| 6 | 3.2s stop | **Raport pomiaru salonu:** - **Szerokość (width):** 1.96 m (pomiędzy ścianami `wall_main_w` i `wall_wc_e`) - **Długość (length):** 2.69 m (pomiędzy ścianami `wall_vest_s` i `wall_office_w`) - **Wysokość (height):** 2.7… | 17,218 in 282 · out 168 · cR 16768 · cW 0 | $0.023 |
Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).
evaluation.json
{
  "objects": {
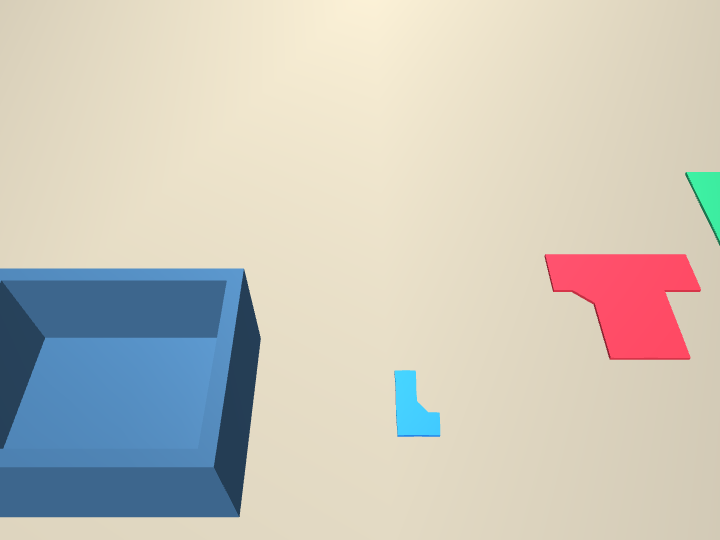
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003981341493557777
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976747703093815
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.0039762428392429786
    }
  },
  "events": [],
  "sim_time_s": 3.763999999999807,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": 4.5047598224383705e-38,
      "handle_angle_rad": -3.293718532894255e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -6.548019428077347e-09,
      "handle_angle_rad": 2.332507939218802e-19,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -2.2575735220521414e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -6.548019428059878e-09,
      "handle_angle_rad": -5.426791797586747e-18,
      "latch_active": true
    },
    "g_wc": {
      "hinge_angle_rad": -6.1044323402293055e-09,
      "handle_angle_rad": -2.755194612991635e-17,
      "latch_active": true
    },
    "g_vestibule": {
      "hinge_angle_rad": -6.1044323402293055e-09,
      "handle_angle_rad": -2.755194612991635e-17,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -6.5480194280647275e-09,
      "handle_angle_rad": -4.3732926685517466e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}