omp-laundry-sonnet55-003
live run · 2026-11-02 17:57 ·
homebot-lab/runs/omp-laundry-sonnet55-003MP4 · 717.1 KB · pełny ekran w playerze
| obiekt | dostarczony | w koszu |
|---|---|---|
| sock_blue | tak | 100% |
| shirt_red | tak | 98% |
| towel_green | nie | 0% |
skilllaundry
modelanthropic/claude-sonnet-5.5
profilgpu
LLM / koszt21 calli · $0.509
ag. limity20 req · 11 seq · 24 tools
czas misji143.9s
status agentarobot_stop_latched
calle LLM
21
tool calls
24
koszt zadania
$0.509
tokeny (sum)
495,930
in / out
4,767 / 8,255
cache R/W
329,285 / 153,623
czas modelu
112.4s
Calle LLM na zadanie
| # | czas | co zrobił (tool + wynik) | tokeny | koszt |
|---|---|---|---|---|
| 1 | 2.0s toolUse | robot_capabilities discover mode=SIMULATION_ONLY mission_memory_read read notes {"revision":0,"agent_notes":null} robot_observe initial observation {"observation_id":"obs-cc02f55e-1-350","session_id":"cc02f55e","time_s":0.7,"rgb_path":"/home/pawel/Documents/homebot-l… | 9,688 in 4 · out 151 · cR 0 · cW 9533 | $0.025 |
| 2 | 6.2s toolUse | robot_execute_sequence grasp sock, test lift ok · move_tcp → move_tcp → close_gripper → move_tcp → wait · F=0.94N · grip=yes | 13,858 in 527 · out 580 · cR 9533 · cW 3218 · reason 340 | $0.016 |
| 3 | 1.8s toolUse | robot_observe verify sock lift {"observation_id":"obs-cc02f55e-2-2938","session_id":"cc02f55e","time_s":5.876,"rgb_path":"/home/pawel/Documents/homebo… | 13,679 in 2 · out 54 · cR 12751 · cW 872 | $0.0040 |
| 4 | 8.5s toolUse | robot_execute_sequence raise sock and move toward bin ok · move_tcp → move_tcp → wait · F=0.29N · grip=yes | 17,025 in 527 · out 742 · cR 13623 · cW 2133 · reason 534 | $0.015 |
| 5 | 7.4s toolUse | robot_observe check sock {"observation_id":"obs-cc02f55e-3-5230","session_id":"cc02f55e","time_s":10.46,"rgb_path":"/home/pawel/Documents/homebo… | 16,942 in 2 · out 356 · cR 15756 · cW 828 · reason 304 | $0.0072 |
| 6 | 6.8s toolUse | robot_execute_sequence drop sock in bin ok · move_tcp → move_tcp → open_gripper → wait → move_tcp · F=0.30N · grip=no | 19,816 in 527 · out 613 · cR 16584 · cW 2092 · reason 374 | $0.014 |
| 7 | 4.3s toolUse | robot_observe verify sock in bin {"observation_id":"obs-cc02f55e-4-6730","session_id":"cc02f55e","time_s":13.46,"rgb_path":"/home/pawel/Documents/homebo… | 19,722 in 2 · out 175 · cR 18676 · cW 869 · reason 119 | $0.0058 |
| 8 | 6.5s toolUse | mission_memory_write progress {"revision":1,"kind":"agent_mission_notes","notes":"sock_blue: grasp1 ok, lifted, dropped in bin, visible in bin (parti… robot_execute_sequence grasp shirt, test lift ok · move_tcp → move_tcp → close_gripper → move_tcp → wait · F=1.08N · grip=yes | 22,857 in 527 · out 698 · cR 19545 · cW 2087 · reason 304 | $0.015 |
| 9 | 2.2s toolUse | robot_observe verify shirt lift {"observation_id":"obs-cc02f55e-5-10610","session_id":"cc02f55e","time_s":21.22,"rgb_path":"/home/pawel/Documents/homeb… | 22,916 in 2 · out 55 · cR 21632 · cW 1227 | $0.0058 |
| 10 | 6.9s toolUse | robot_execute_sequence lift shirt high, shift toward bin ok · move_tcp → move_tcp → wait · F=1.48N · grip=yes | 26,109 in 527 · out 625 · cR 22859 · cW 2098 · reason 413 | $0.015 |
| 11 | 2.7s toolUse | robot_observe check shirt {"observation_id":"obs-cc02f55e-6-13977","session_id":"cc02f55e","time_s":27.954,"rgb_path":"/home/pawel/Documents/home… | 25,844 in 2 · out 52 · cR 24957 · cW 833 | $0.0051 |
| 12 | 12.2s toolUse | robot_execute_sequence shift shirt toward bin ok · move_tcp → wait · F=1.47N · grip=yes | 29,081 in 527 · out 1191 · cR 0 · cW 27363 · reason 1007 | $0.081 |
| 13 | 2.8s toolUse | robot_observe check {"observation_id":"obs-cc02f55e-7-15074","session_id":"cc02f55e","time_s":30.148,"rgb_path":"/home/pawel/Documents/home… | 28,213 in 2 · out 49 · cR 27363 · cW 799 | $0.0052 |
| 14 | 6.9s toolUse | robot_execute_sequence move shirt over bin center and release ok · move_tcp → move_tcp → open_gripper → wait · F=1.49N · grip=no | 30,794 in 527 · out 566 · cR 0 · cW 29701 · reason 347 | $0.081 |
| 15 | 3.7s toolUse | robot_execute_sequence retract arm up rejected | 30,728 in 2 · out 179 · cR 29701 · cW 846 | $0.0069 |
| 16 | 2.3s toolUse | robot_observe verify shirt in bin {"observation_id":"obs-cc02f55e-8-16844","session_id":"cc02f55e","time_s":33.688,"rgb_path":"/home/pawel/Documents/home… | 30,809 in 2 · out 56 · cR 30547 · cW 204 | $0.0041 |
| 17 | 12.1s toolUse | robot_execute_sequence stow arm before driving ok · move_tcp → move_tcp · F=0.00N · grip=no mission_memory_write progress {"revision":2,"kind":"agent_mission_notes","notes":"sock_blue and shirt_red released in bin, visible in bin image (part… | 33,796 in 527 · out 991 · cR 0 · cW 32278 · reason 625 | $0.092 |
| 18 | 7.0s toolUse | robot_move_base approach towel rejected | 34,062 in 2 · out 580 · cR 32278 · cW 1202 · reason 384 | $0.012 |
| 19 | 3.1s toolUse | robot_observe post-stow {"observation_id":"obs-cc02f55e-9-19030","session_id":"cc02f55e","time_s":38.06,"rgb_path":"/home/pawel/Documents/homeb… | 33,754 in 2 · out 52 · cR 33480 · cW 220 | $0.0044 |
| 20 | 7.0s toolUse | robot_move_base approach towel forward collision_guard | 36,237 in 527 · out 490 · cR 0 · cW 35220 · reason 295 | $0.094 |
| 21 | — aborted | — | 0 in 0 · out 0 | — |
Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).
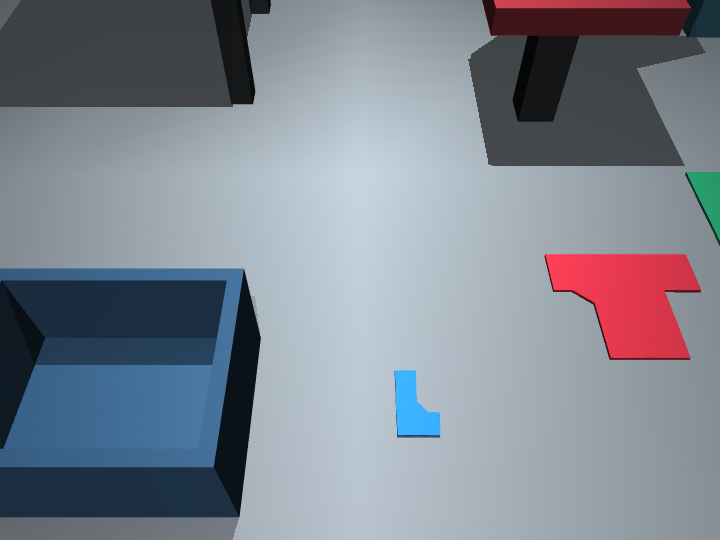
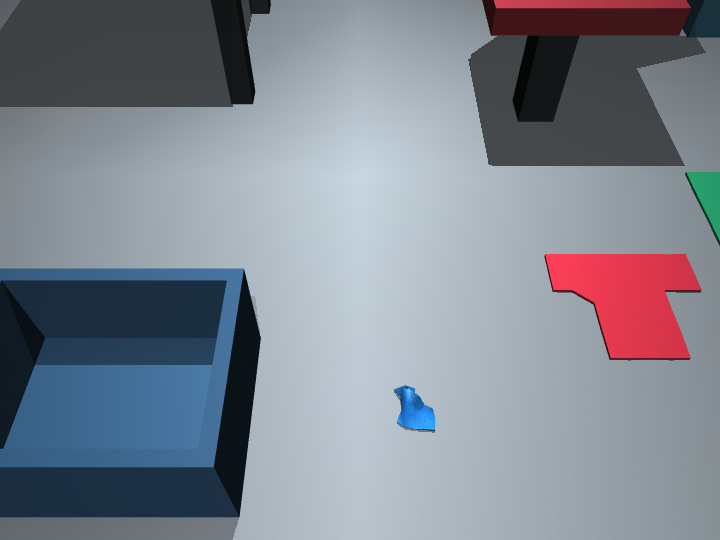
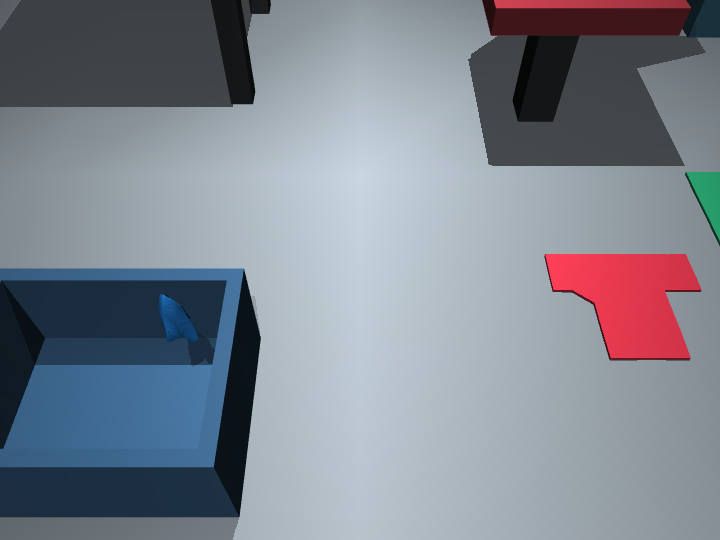
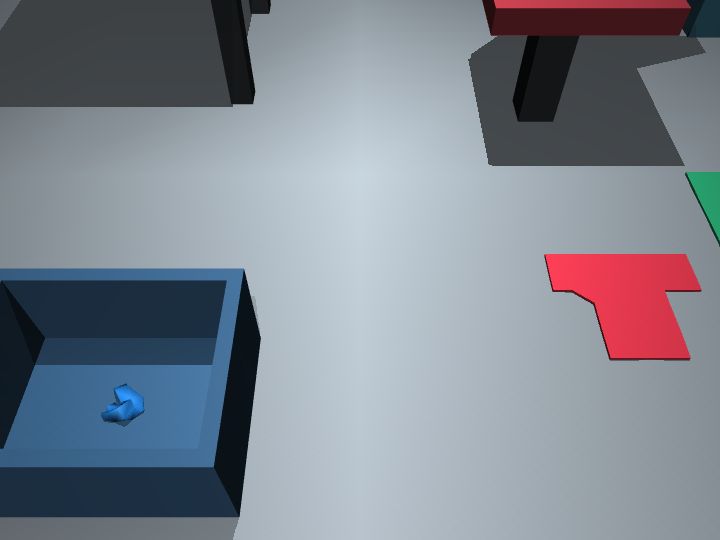
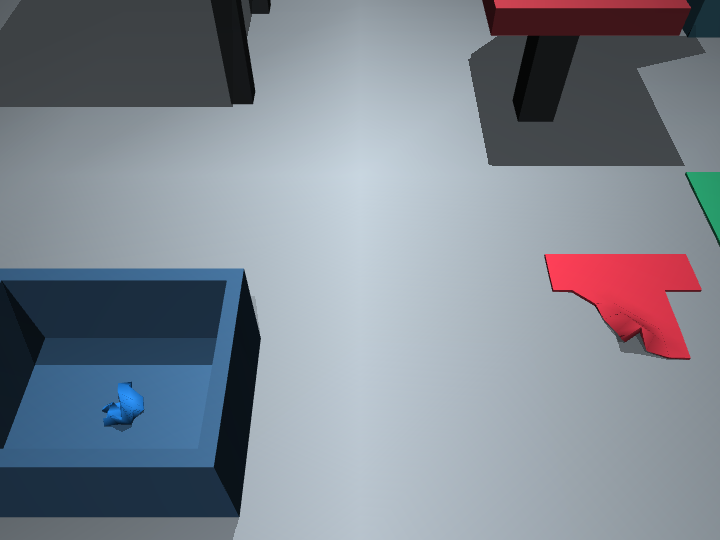
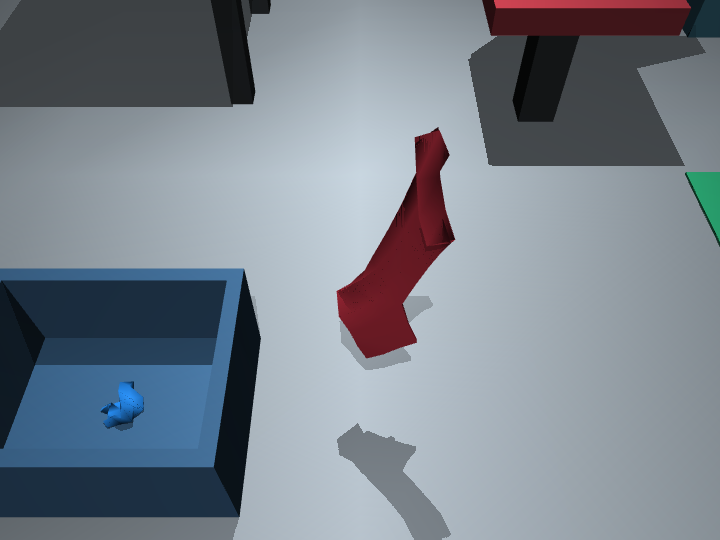
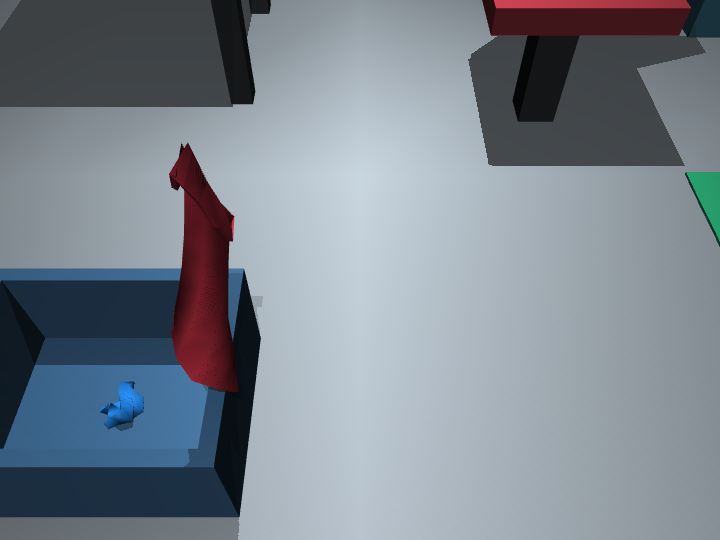
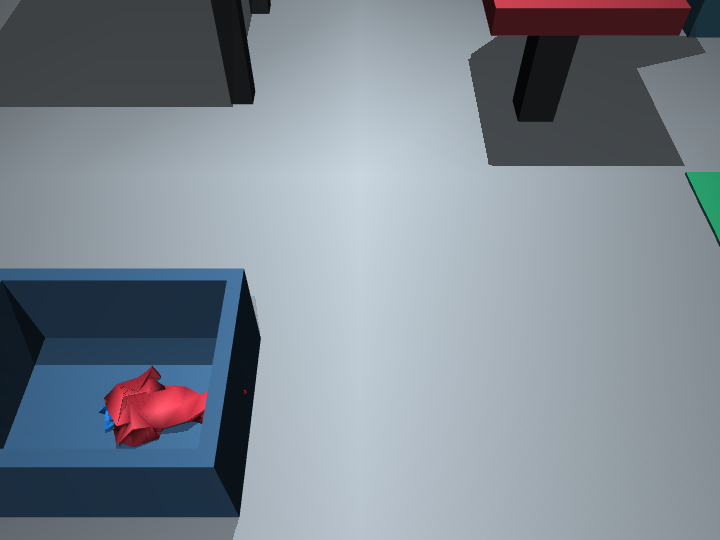
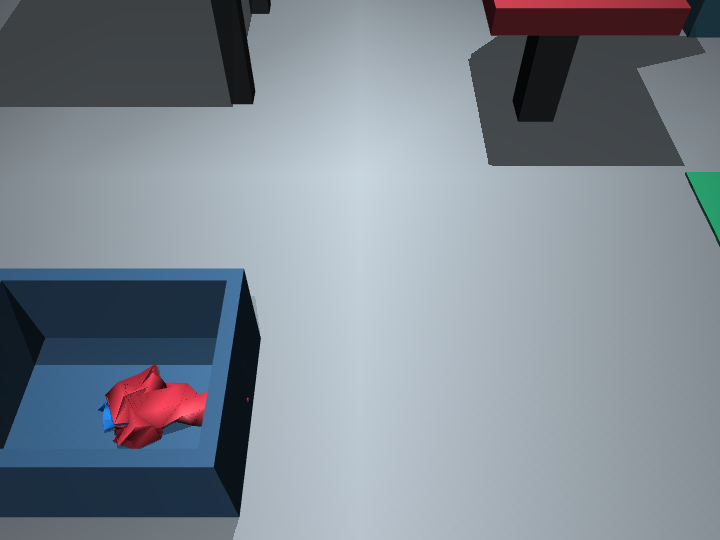
evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 1.0,
      "delivered": true,
      "max_z_m": 0.0672215530967116
    },
    "shirt_red": {
      "fraction_in_bin": 0.984,
      "delivered": true,
      "max_z_m": 0.10447377161489912
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976073452433393
    }
  },
  "events": [],
  "sim_time_s": 38.06000000000055,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor"
}